


ESP32 Custom Flight Controller
CLIENT
Independent Research
YEAR
2026
INDUSTRY
Aerospace Software & Hardware
SERVICES
UAVs & Autonomy · Embedded
Key Highlights
Real-Time Sensor Fusion & Kinematics
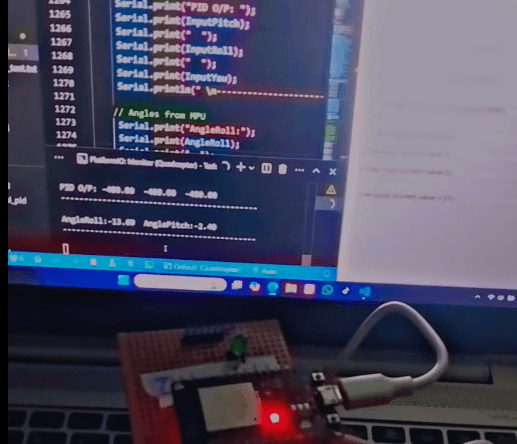
Engineered a bare-metal flight controller from scratch using an ESP32 DevKit V1 and an MPU6050 IMU communicating via 400kHz I2C. Implemented a continuous 1D Kalman filter in the main control loop to fuse accelerometer and gyroscope data, stripping out physical vibration noise to calculate highly accurate roll and pitch angles.
Wireless PID Tuning & Web Control
Eliminated the need to repeatedly re-flash the board during flight testing by writing an embedded HTML/JS web server directly on the ESP32. This allows for live updating of Proportional, Integral, and Derivative gains over Wi-Fi, writing the new variables permanently to onboard SPIFFS non-volatile memory.


Network-Capable Hardware Architecture
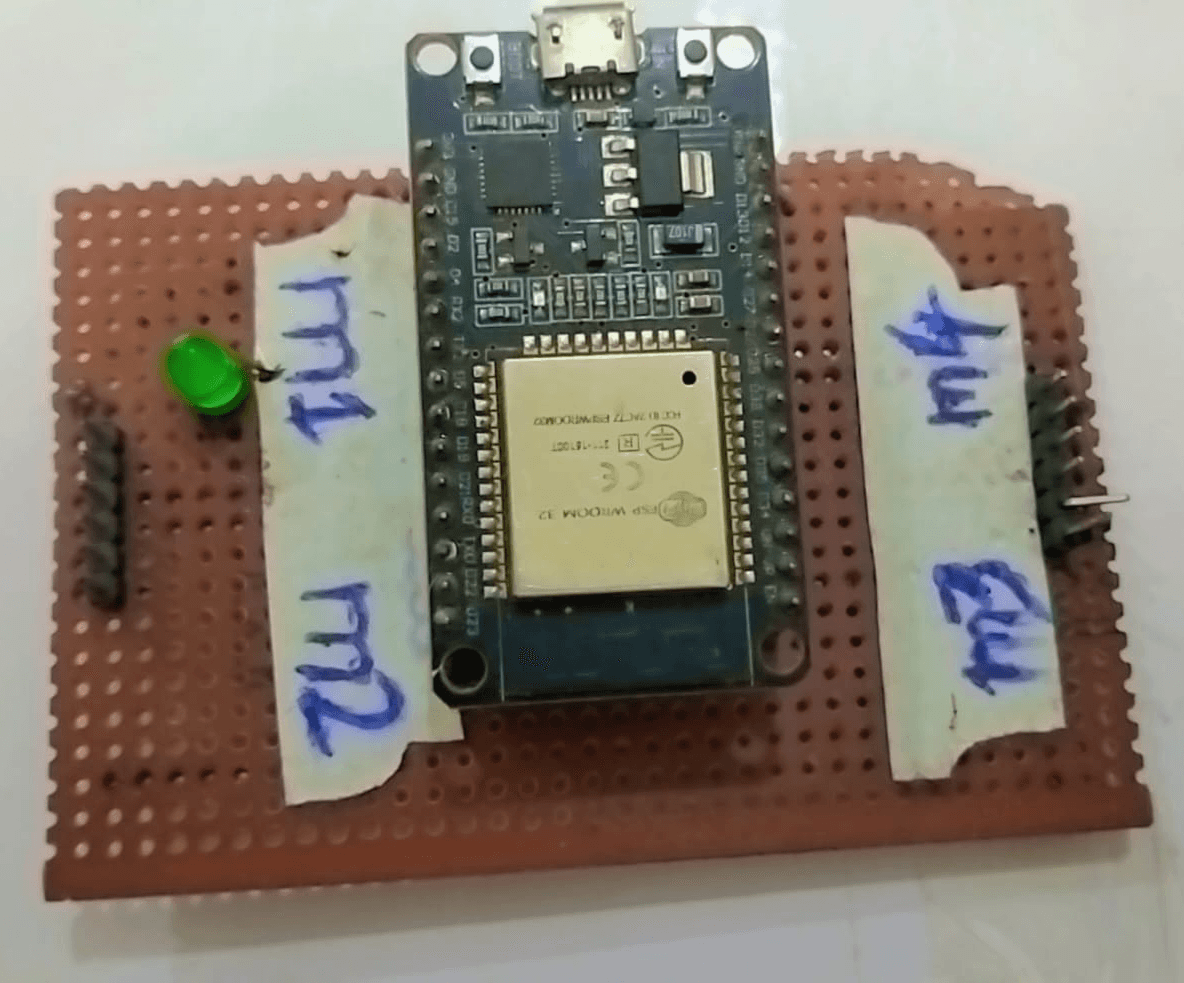
Successfully built a stable, budget-friendly flight controller capable of bypassing traditional RC radio inputs entirely. The system translates incoming WebSocket strings from a laptop keyboard into precise PWM signals sent to brushless motor ESCs, complete with hardcoded failsafe cutoffs.
Designed for measurable product growth
Every design decision focused on improving usability, increasing engagement.
400kHz
I2C Clock Speed
High-speed communication protocol for the MPU6050 IMU.
1050us
Failsafe Threshold
Automatic throttle cutoff logic to prevent uncommanded spin-ups.
100%
Remote Configurable
Full PID tuning and flight control executed wirelessly via browser.

