Lewius Gordon

Lewius Gordon

Art Director

background
avatar

Shah Zaman Haider

Robotics Engineer

Robotics & Autonomous Systems Engineer | ROS 2, UAVs & Edge AI | Published Researcher | Founder of Robetix

Lewius Gordon

@shahzaman

Open to Research Opportunities

Based in

Pakistan

Hi, I'm Shah Zaman Haider

I build systems that sense, decide, act.

Robotics & Autonomous Systems Engineer based in Pakistan

Selected Works

Robotics projects built for
real-world problems.

©
2023-26

🏆 1st Place, IEEE Senior Design Exhibition 2026 · Founder, Robetix · Delivered to Clients in 12+ Countries

UAV & Flight Control

Embedded & Real-Time Control

ROS 2 & Simulation

Ground Control & Integration

var(--variable-pZqL61UMU)

UAV & Flight Control

Embedded & Real-Time Control

ROS 2 & Simulation

Ground Control & Integration

var(--variable-pZqL61UMU)

Research

RESEARCH & ENGINEERING

Research shaped by real systems. Building and testing robots has raised practical questions around perception, heat, communication, localization, and control. Current direction: reliable autonomous robots that keep working when conditions become difficult. Open to graduate research, R&D opportunities, and selected robotics projects.


25 ms32 ms15 → 12 FPS34°C ambient76°C processor88% temporary false detections rejected
UAVGround180 m stable>200 m degradedvideo delay up to 3 sonboard processing continues
ROS 2 / CartographerRGB-D + Jetson NanoSimulation → Field±1.5 m tolerance
attitude axesPID settles to hover targetESP32 / MPU6050 / live PIDESP32-CAM / bare-metal 8051
25 ms32 ms15 → 12 FPS34°C ambient76°C processor88% temporary false detections rejected

01

Onboard Perception in Real Conditions

YOLOv8 Nano initially ran at 25 ms per frame (~15 FPS) on a Raspberry Pi 5. During sustained operation in 34°C ambient heat, inference increased to 32 ms as the processor reached 76°C. A five-frame verification method rejected 88% of temporary false detections during field tests.
UAVGround180 m stable>200 m degradedvideo delay up to 3 sonboard processing continues

02

Autonomy with Unreliable Communication

The UAV maintained stable video and MAVLink telemetry to 180 m over a 5 GHz link. Beyond 200 m, packet loss caused video delays of up to 3 seconds, while onboard detection continued to run. This made local decision-making an important part of the system design.

ROS 2 / CartographerRGB-D + Jetson NanoSimulation → Field±1.5 m tolerance

03

Localization, Mapping & Navigation

Research work at NCAI included ROS 2 Jazzy, Gazebo, URDF/XACRO, Cartographer SLAM, and Azure Kinect integration with Jetson Nano. In later UAV field tests, GPS-guided navigation reached a measured lateral tolerance of ±1.5 m.

attitude axesPID settles to hover targetESP32 / MPU6050 / live PIDESP32-CAM / bare-metal 8051

04

Embedded Flight & Control

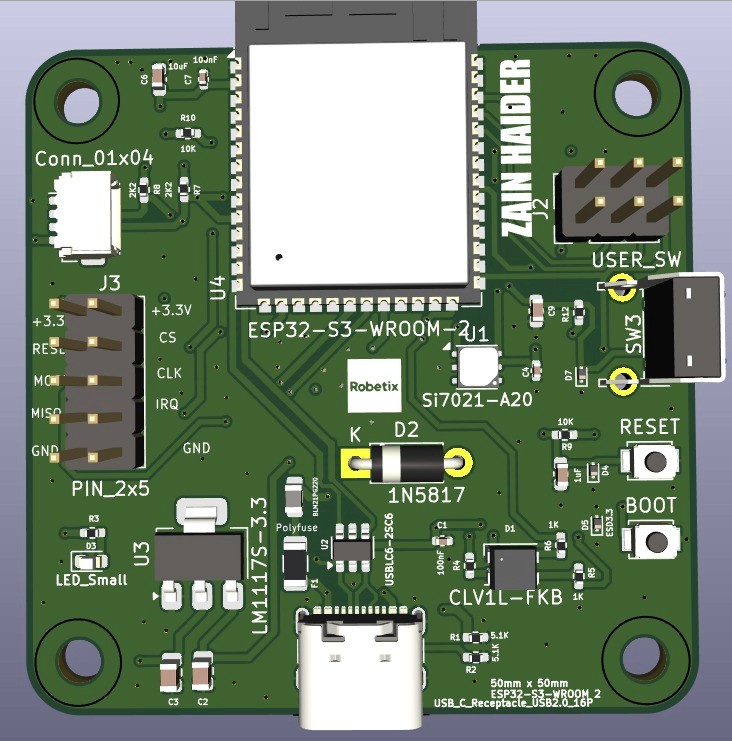
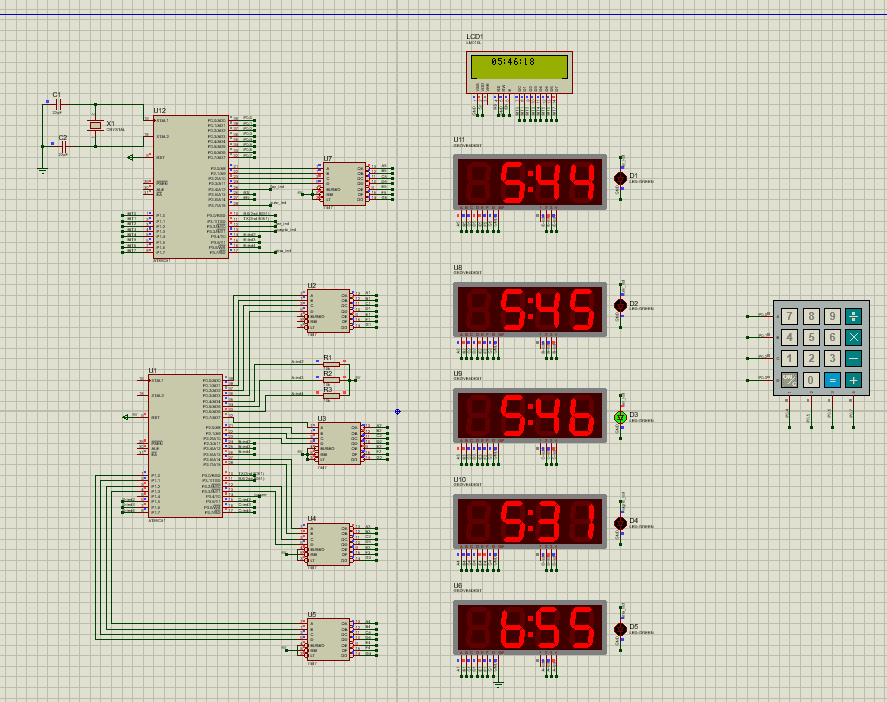
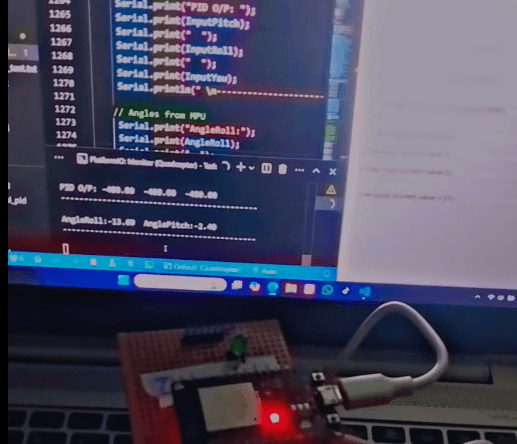
A custom ESP32 + MPU6050 flight controller achieved stable hover and attitude control, with PID gains adjustable live through a browser interface. Other embedded work includes local vision-based motor control on ESP32-CAM and bare-metal firmware development on the 8051.

Discuss an Opportunity →

Process

How I build systems

Every build starts with the limit most likely to shape the system, weight, power, sensing, control, compute, or range. I test that early, integrate the subsystems around it, then validate the complete system with real measurements.

04 Steps

Step 01

Set the limits

Payload

Logo Design

Power

Logo Design

Range

Logo Design

Step 02

Prove the critical part

Flight Stability

Logo Design

SLAM

Logo Design

Onboard Vision

Logo Design

Step 03

Integrate the system

Companion Comp

Logo Design

Middleware

Logo Design

Sensors & Control

Logo Design

Step 04

Test in the field

Latency

Logo Design

Accuracy

Logo Design

Endurance

Logo Design

180 m

Stable telemetry range

UAV testing covered communication range, waypoint accuracy, inference speed under heat, and flight time. The video and MAVLink link stayed stable up to 180 m, which made it easier to see where the system was reliable and where it still needed work.

EXPERIENCE

Work beyond the classroom

Lead Systems Integrator — Robetix

Jan 2025 — Present

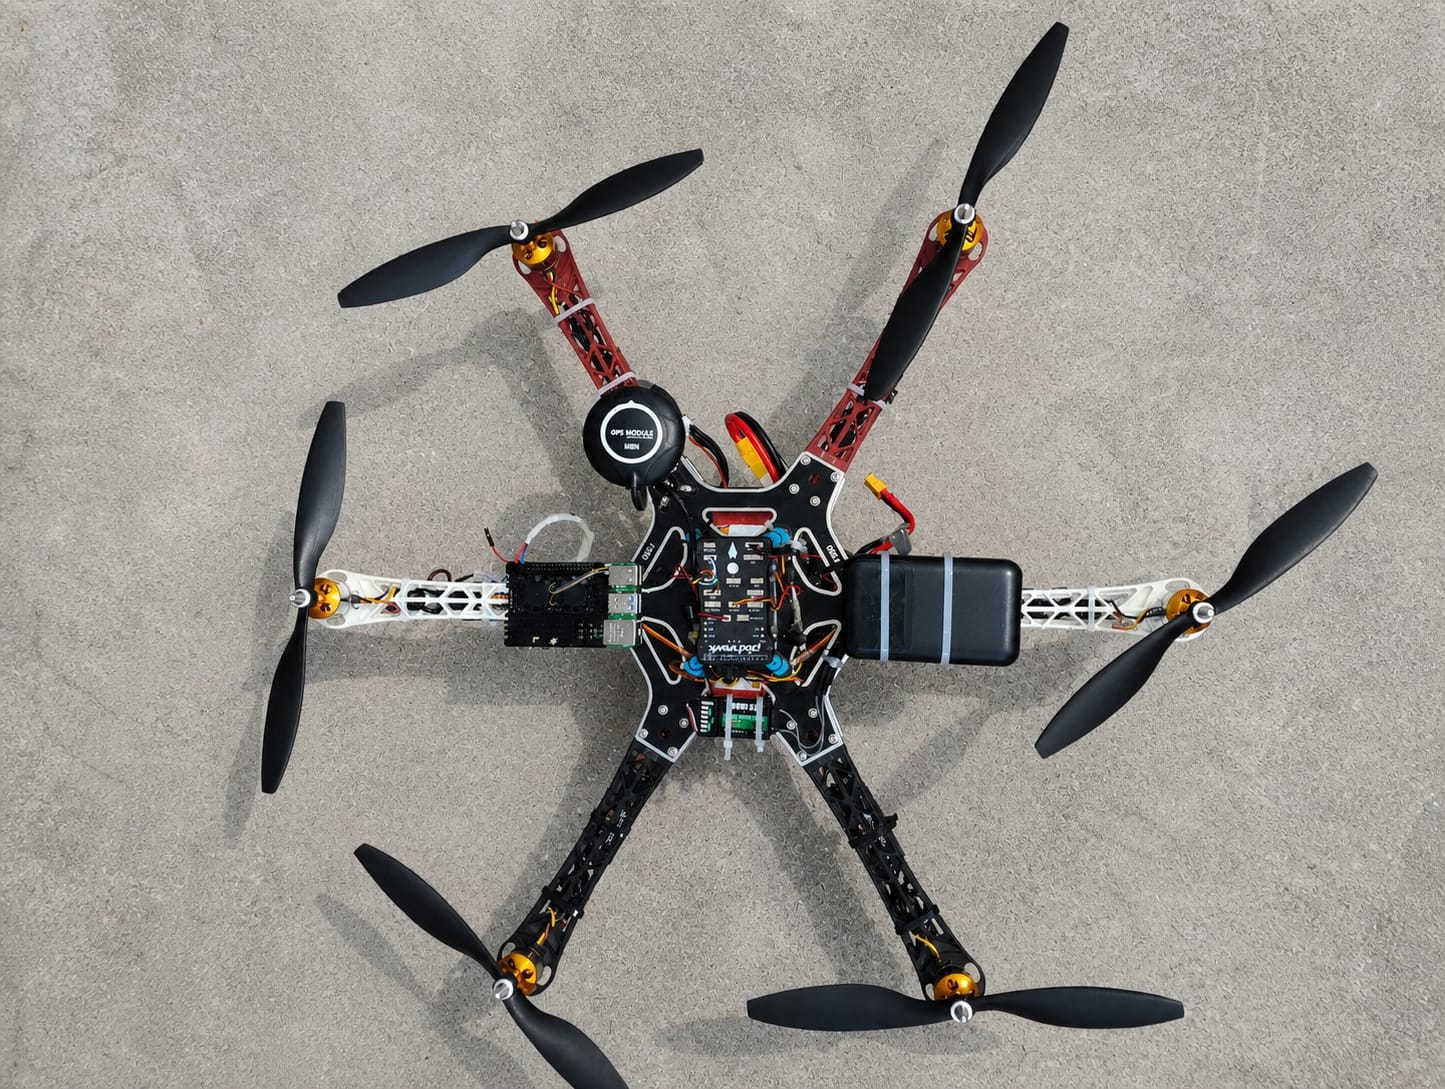
Delivered embedded and robotics systems across 20+ client projects, including a GPS-enabled custom quadcopter shipped to Germany and validated under a 1 kg payload.

Robotics Research Intern — NCAI, NUST

Jul 2025 — Sep 2025

Selected from 1,500+ applicants for the National Internship Program. Worked on ROS 2 Jazzy, Gazebo simulation, Cartographer SLAM, and Azure Kinect–Jetson Nano integration.

Robotics & Embedded Systems Mentor — IUB

2024 — Present

Mentored junior teams in component selection, circuit debugging, and embedded firmware, including IoT systems and ongoing work on an EMG-controlled wheelchair.

Technical Content Creator — Robetix

Apr 2019 — Jun 2025

Six years of technical video creation, moving toward robotics and embedded systems while building experience in explaining engineering concepts clearly on camera.

CLIENT FEEDBACK

What people
say about the work

Client portrait
Client portrait
Client portrait

Trusted by

global clients

Michael Brooks
Ava Mitchell
Liam Carter

2 Weeks

Embedded Systems & IoT

“the best person i have ever worked with in fiverr he is acurate in delivery, + he fixed my mistakes in my proejct thanks to him my project is ready all the respesct emran shah zaman. i recommend him 100/100”

Horizon Studio logo

menweralhadedit

Student, Germany

Michael Brooks
Ava Mitchell
Liam Carter

Impactful

Strategic

“His direction completely transformed how we present ourselves digitally. The work feels minimal yet powerful, and every detail is intentional. It’s design that actually moves the business forward.”

Horizon Studio logo

Michael Brooks

Founder, Horizon Studio

Toolkit

Tools I build with

A practical toolkit built through robotics, embedded systems, simulation, perception, and hardware integration.

ROS 2 & Simulation

ROS 2 Jazzy · Gazebo · RViz · Nav2 · URDF/XACRO

Autonomy & Flight

Pixhawk · ArduPilot · MAVLink · MAVROS · Mission Planner

Embedded Systems

ESP32 · Raspberry Pi · Jetson Nano · 8051

Programming

C/C++ · Python · Embedded C · Linux

Perception & Sensing

OpenCV · YOLOv8 · Azure Kinect · Camera/Sensor Integration

Electronics & Interfaces

PCB Design · UART · I2C · SPI · PWM · ADC

Archive

IEEE Senior Design Project Exhibition first-place award for autonomous disaster response drone
Autonomous search and rescue hexacopter developed by Shah Zaman Haider
IEEE Senior Design Project Poster
Custom ground control station for autonomous UAV field testing

FAQ

Questions about my research, robotics work, and collaboration.

Still have a question? Send me an email

What opportunities are you open to?

What kind of technical work do you take on?

Robotics and autonomous systems, ROS 2, embedded systems, UAVs, sensor integration, and edge perception.

How do you usually start a collaboration?

Where can I find more technical detail?

Contact

Have a robotics problem worth solving?

Open to graduate research, robotics R&D, collaborations, and selected engineering projects. Share the opportunity or technical problem and I’ll get back to you.