



ROS 2 URDF Vehicle Simulation
CLIENT
Personal Research
YEAR
2025
INDUSTRY
Robotics Software
SERVICES
ROS 2 & Edge AI
Key Highlights
URDF & XACRO Modeling
Developed a kinematic vehicle model using Unified Robot Description Format (URDF) integrated with XACRO. The XML-based architecture defines the exact physical properties, joint limits, and spatial transforms required for accurate representation within the ROS 2 ecosystem.
State Publishing & TF Tree
Configured the robot_state_publisher and joint_state_publisher nodes to execute concurrently. This architecture reads the URDF parameters and continuously broadcasts the position and orientation of all structural links to the /tf topic, ensuring real-time spatial tracking.


Unified Package Deployment
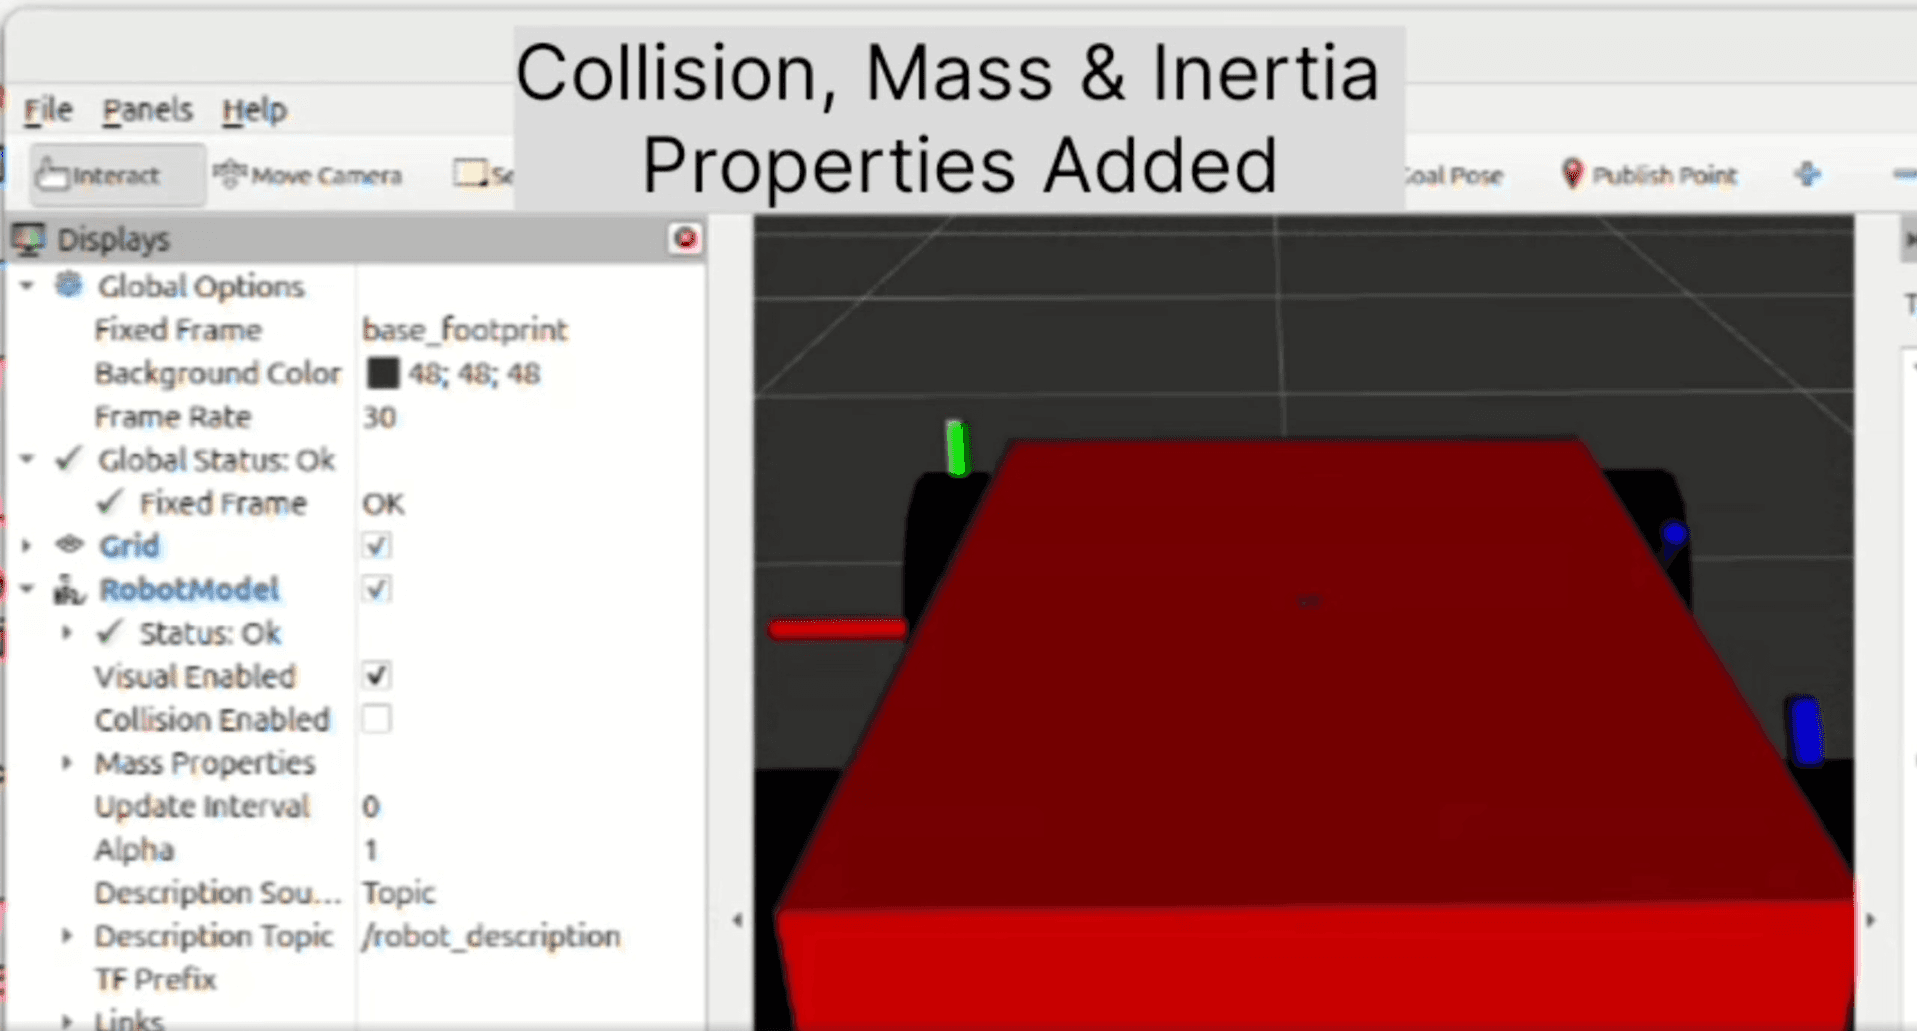
Successfully validated the kinematic chain and transforms of the vehicle model within RViz. The individual components and nodes were subsequently structured into a single, cohesive ROS 2 package, allowing the entire simulation environment to be spun up using a single launch command.
Designed for measurable product growth
Every design decision focused on improving usability, increasing engagement.
2
Concurrent Nodes
Synchronized joint and robot state publishers for real-time tf broadcasting.
100%
XACRO Integration
Utilized macro-based XML generation for modular and scalable robot design.
/tf
Transform Topic
Accurately tracked all spatial frame transforms within the RViz environment.

